
Legged navigation & traversability
Where can a legged robot step, and how should it get there? Semantic and geometric traversability, footstep and path planning, world models.
Robotics · Cognition · Learning
Professor in Robotics and AI, UCL Computer Science · UKRI Future Leaders Fellow · Head of the Intelligent Robotics Group and the RPL Lab
Robots are no longer short of bodies. What they lack is judgement. My group builds the cognitive layer — perception, mapping, and task/path planning — that lets legged robots work out where they are, what is around them and what to do next, in terrain and clutter too unpredictable for scripted behaviour. Our methods run on more than a dozen humanoid and quadruped platforms.

Where can a legged robot step, and how should it get there? Semantic and geometric traversability, footstep and path planning, world models.

Real-time metric-semantic mapping, structure-free topometric maps, visual localisation with few images, dense RGB-D SLAM on embedded devices.

Reliable autonomy in hazardous, unstructured and GPS-denied environments: risk-aware planning, uncertainty estimation, failure recovery and field deployment.
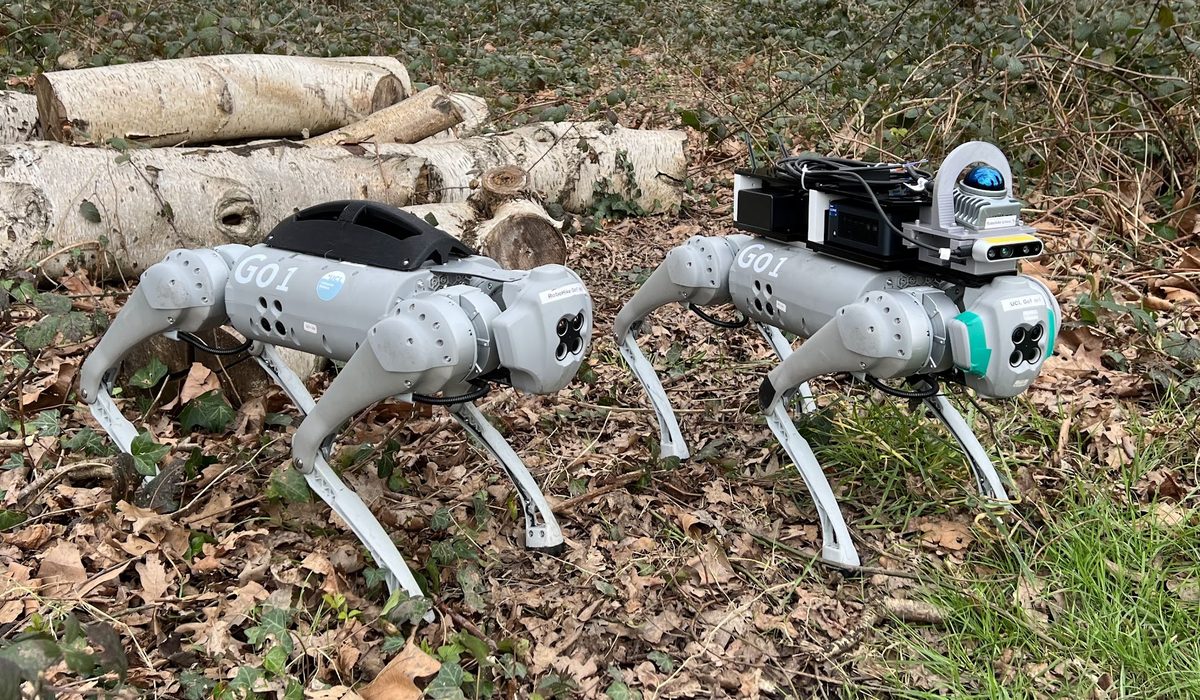
Teams of heterogeneous legged and wheeled robots that share maps, allocate tasks and coordinate exploration and inspection.


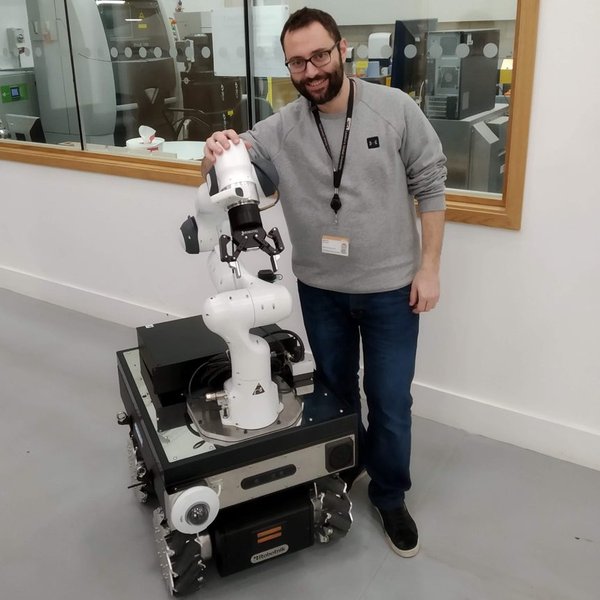


Also: Unitree A1, Go1, Go2, B1 + Z1 arm, Jueying, Summit-XLS, AgileX, MOCA, Pyrène and more.
I advise companies on legged locomotion, robot perception, manipulation and reinforcement learning, and I have served as scientific advisor to several robotics start-ups. If you are building robots that have to work outside the lab, let's talk.
How I can help →